
RESPONSIBILITIES
-
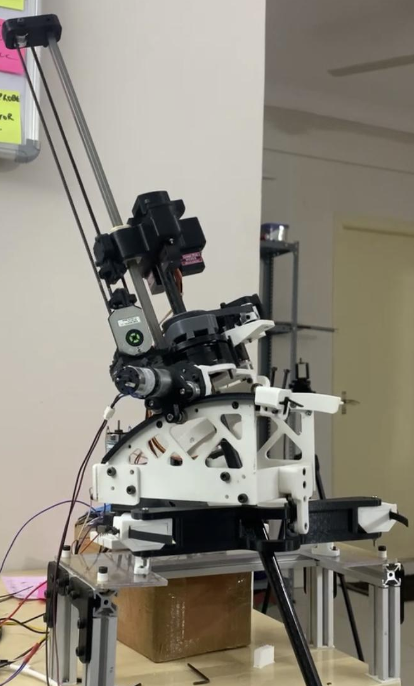
Designing parametric 40+ component assemblies in Fusion360 CAD, to contribute to development of a portable surgical robot system
-
Developing, designing, and prototyping innovative mechanisms to reduce robot size, and optimize joint motion ranges and end-effector forces
-
Validating robot structures and components for structural load cases in ANSYS and Fusion360
-
Preparing and reviewing technical drawings as per ASME Y14.5 standards with GD&T
-
Implementing DFMA techniques during part design to reduce part manufacturing cost and ease assembly process
-
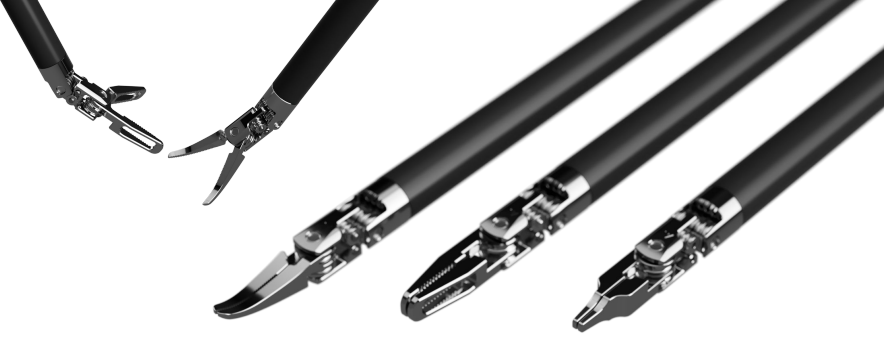
Designing 8 and 12mm surgical tools for metal injection molding process and prototyping using SLA 3D printing
-
Developing and manufacturing testbeds to document end-effector grip force and actuator stall torque in MS Excel